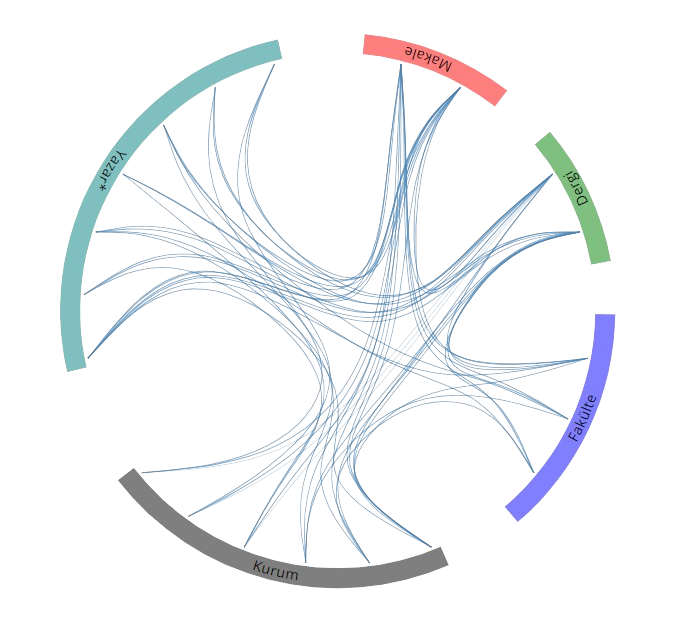
Yayınlar & Eserler

Makaleler 11
Tümü (11)
SCI-E, SSCI, AHCI (8)
SCI-E, SSCI, AHCI, ESCI (10)
ESCI (1)
Scopus (10)
TRDizin (1)
Hakemli Bilimsel Toplantılarda Yayımlanmış Bildiriler 36
1. Simple Dynamic Fusion For RGB-T Semantic Segmentation RGB-T Anlamsal Bölütleme Için Basit Dinamik Füzyon

34th Signal Processing and Communications Applications Conference, SIU 2026, İstanbul, Türkiye, 7 - 10 Temmuz 2026, (Tam Metin Bildiri)

2. Vision Transformer-Based Cross-Modal Change Detection Method for HD Maps HD Haritalar için Görü Dönüştürücü Tabanli Çapraz-Modlu De?gişim Tespiti Yöntemi

34th Signal Processing and Communications Applications Conference, SIU 2026, İstanbul, Türkiye, 7 - 10 Temmuz 2026, (Tam Metin Bildiri)

3. Trajectory Prediction via Velocity Profile-Based Dynamic Model Selection Hiz Profiline Dayali Dinamik Model Seçimi ile Yörünge Tahmini

34th Signal Processing and Communications Applications Conference, SIU 2026, İstanbul, Türkiye, 7 - 10 Temmuz 2026, (Tam Metin Bildiri)

4. Sum of Costs Guided Diffusion for Motion Planning Hareket Planlama için Maliyetlerin Toplami Kilavuzlu Difüzyon

34th Signal Processing and Communications Applications Conference, SIU 2026, İstanbul, Türkiye, 7 - 10 Temmuz 2026, (Tam Metin Bildiri)

5. ANLAMSAL BÖLÜTLEME İLE PİKSEL SEVİYESİNDE ANOMALİ TESPİTİNDE DAĞILIM DIŞI VE DEĞİŞEN BAĞLAMLARDA FARKLI VERİ SETİ KULLANIMI

8. Uluslararası Mühendislik Bilimleri ve Multidisipliner Yaklaşımlar Kongresi, İstanbul, Türkiye, 7 - 08 Aralık 2024, (Tam Metin Bildiri)

6. LAPTNet-FPN: Multi-Scale LiDAR-Aided Projective Transform Network for Real Time Semantic Grid Prediction

2023 IEEE International Conference on Robotics and Automation, ICRA 2023, London, İngiltere, 29 Mayıs - 02 Haziran 2023, cilt.2023-May, ss.712-718, (Tam Metin Bildiri) Creative Commons License

7. LAPTNet: LiDAR-Aided Perspective Transform Network

ICARCV 2022 - 17th International Conference on Control, Automation, Robotics and Vision, Singapur, 11 Aralık 2022, (Tam Metin Bildiri)

8. TransFuseGrid: Transformer-based Lidar-RGB fusion for semantic grid prediction

ICARCV 2022-17th International Conference on Control, Automation, Robotics and Vision, Singapur, 11 Aralık 2022, (Tam Metin Bildiri)

9. Frustum-PointPillars: A Multi-Stage Approach for 3D Object Detection using RGB Camera and LiDAR

IEEE/CVF International Conference on Computer Vision (ICCV) Workshops, Alabama, Amerika Birleşik Devletleri, 17 Ekim 2021 - 18 Ekim 2022, ss.2926-2933, (Tam Metin Bildiri)

10. MultiLane: Lane Intention Prediction and Sensible Lane-Oriented Trajectory Forecasting on Centerline Graphs

25th IEEE International Conference on Intelligent Transportation Systems, ITSC 2022, Macau, Çin, 8 - 12 Ekim 2022, cilt.2022-October, ss.3657-3664, (Tam Metin Bildiri) Creative Commons License

11. YOLO-based Panoptic Segmentation Network

IEEE 45TH ANNUAL COMPUTERS, SOFTWARE, AND APPLICATIONS CONFERENCE (COMPSAC 2021), İspanya, 12 Temmuz 2021, (Tam Metin Bildiri)

12. GridTrack: Detection and Tracking of Multiple Objects in Dynamic Occupancy Grids

13th International Conference on Computer Vision Systems, ICVS 2021, Virtual, Online, 22 - 24 Eylül 2021, cilt.12899 LNCS, ss.180-194, (Tam Metin Bildiri)

13. GndNet: Fast ground plane estimation and point cloud segmentation for autonomous vehicles

2020 IEEE/RSJ International Conference on Intelligent Robots and Systems, IROS 2020, Nevada, Amerika Birleşik Devletleri, 24 Ekim 2020 - 24 Ocak 2021, ss.2150-2156, (Tam Metin Bildiri) Creative Commons License

14. Instance Segmentation with Unsupervised Adaptation to Different Domains for Autonomous Vehicles

16th IEEE International Conference on Control, Automation, Robotics and Vision (ICARCV), Shenzhen, Çin, 13 - 15 Aralık 2020, ss.421-427, (Tam Metin Bildiri) Creative Commons License

15. Leveraging Dynamic Occupancy Grids for 3D Object Detection in Point Clouds

16th IEEE International Conference on Control, Automation, Robotics and Vision (ICARCV), Shenzhen, Çin, 13 - 15 Aralık 2020, ss.1188-1193, (Tam Metin Bildiri) Creative Commons License

16. Recognize Moving Objects Around an Autonomous Vehicle Considering a Deep-learning Detector Model and Dynamic Bayesian Occupancy

16th IEEE International Conference on Control, Automation, Robotics and Vision (ICARCV), Shenzhen, Çin, 13 - 15 Aralık 2020, ss.414-420, (Tam Metin Bildiri) Creative Commons License

17. Attentional PointNet for 3D-Object Detection in Point Clouds

32nd IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), California, Amerika Birleşik Devletleri, 16 - 20 Haziran 2019, ss.1297-1306, (Tam Metin Bildiri) Creative Commons License

18. Semantic Grid Estimation with a Hybrid Bayesian and Deep Neural Network Approach

25th IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Madrid, İspanya, 1 - 05 Ekim 2018, ss.888-895, (Tam Metin Bildiri) Creative Commons License

19. Semantic Grid Estimation with Occupancy Grids and Semantic Segmentation Networks

15th International Conference on Control, Automation, Robotics and Vision (ICARCV), Singapore, Singapur, 18 - 21 Kasım 2018, ss.1051-1056, (Tam Metin Bildiri) Creative Commons License

20. Modeling Driver Behavior From Demonstrations in Dynamic Environments Using Spatiotemporal Lattices

IEEE International Conference on Robotics and Automation (ICRA), Brisbane, Avustralya, 21 - 25 Mayıs 2018, ss.3384-3390, (Tam Metin Bildiri) Creative Commons License

21. It Gets Worse Before it Gets Better: Timing of Instructions in Close Human-Robot Collaboration

2017 ACM/IEEE International Conference on Human-Robot Interaction, New York, Amerika Birleşik Devletleri, 01 Mart 2017, (Tam Metin Bildiri)

22. Visual Task Outcome Verification Using Deep Learning

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) / Workshop on Machine Learning Methods for High-Level Cognitive Capabilities in Robotics, Vancouver, Kanada, 24 - 28 Eylül 2017, ss.4821-4827, (Tam Metin Bildiri)

23. Proactive, Incremental Learning of Gesture-Action Associations For Human-Robot Collaboration

26th IEEE International Symposium on Robot and Human Interactive Communication (RO-MAN), Lisbon, Portekiz, 28 Ağustos - 01 Eylül 2017, ss.346-353, (Tam Metin Bildiri)

24. Supervised learning of gesture-action associations for human-robot collaboration

12th IEEE International Conference on Automatic Face and Gesture Recognition (FG), Washington, Kiribati, 30 Mayıs - 03 Haziran 2017, ss.778-783, (Tam Metin Bildiri)

25. A Multi-View Hand Gesture RGB-D Dataset for Human-Robot Interaction Scenarios

25th IEEE International Symposium on Robot and Human Interactive Communication (IEEE RO-MAN), New York, Amerika Birleşik Devletleri, 26 - 31 Ağustos 2016, ss.1084-1091, (Tam Metin Bildiri)

26. Integration of Probabilistic Pose Estimates from Multiple Views

14th European Conference on Computer Vision (ECCV), Amsterdam, Hollanda, 8 - 16 Ekim 2016, cilt.9911, ss.154-170, (Tam Metin Bildiri)

27. Human Smile Distinguishes between Collaborative and Solitary Tasks in Human-Robot Interaction

Proceedings of the Tenth Annual ACM/IEEE International Conference on Human-Robot Interaction Extended Abstracts, New York, Amerika Birleşik Devletleri, 02 Mart 2015, (Özet Bildiri)

28. Long-Term Topological Place Learning

IEEE International Conference on Robotics and Automation (ICRA), Washington, Amerika Birleşik Devletleri, 26 - 30 Mayıs 2015, ss.5462-5467, (Tam Metin Bildiri)

29. General Object Tip Detection and Pose Estimation for Robot Manipulation

10th International Conference on Computer Vision Systems (ICVS), Copenhagen, Danimarka, 6 - 09 Temmuz 2015, cilt.9163, ss.364-374, (Tam Metin Bildiri) Creative Commons License

30. Probabilistic detection of pointing directions for human-robot interaction

International Conference on Digital Image Computing: Techniques and Applications, Adelaide, Avustralya, 23 - 25 Kasım 2015, ss.601-608, (Tam Metin Bildiri) Creative Commons License

31. The Effects of Social Gaze in Human-Robot Collaborative Assembly

7th International Conference on Social Robotics (ICSR), Paris, Fransa, 26 - 30 Ekim 2015, cilt.9388, ss.204-213, (Tam Metin Bildiri) Sürdürülebilir Kalkınma

32. Integrating Cue Descriptors in Bubble Space for Place Recognition

International Conference on Computer Vision Systems, St. Petersburg, Rusya, 16 Temmuz 2013, (Tam Metin Bildiri)

33. Place Representation in Topological Maps Based on Bubble Space

IEEE International Conference on Robotics and Automation (ICRA), Minnesota, Amerika Birleşik Devletleri, 14 - 18 Mayıs 2012, ss.3497-3502, (Tam Metin Bildiri) Sürdürülebilir Kalkınma

34. Attentive vision, scene representation and bubble space Görsel i̇lgi, ortam betimleme ve baloncuk uzayi

18th IEEE Signal Processing and Communications Applications Conference, SIU 2010, Diyarbakır, Türkiye, 22 - 24 Nisan 2010, ss.387-390, (Tam Metin Bildiri)

35. Color in Attention Control

IEEE 17th Signal Processing and Communications Applications Conference, Antalya, Türkiye, 9 - 11 Nisan 2009, ss.467-470, (Tam Metin Bildiri)

36. Saccades and fixating using artificial potential functions

IEEE/RSJ International Conference on Intelligent Robots and Systems, Beijing, Çin, 9 - 13 Ekim 2006, ss.5819-5820, (Tam Metin Bildiri)
Metrikler

Yayın

47

Yayın (WoS)

32

Yayın (Scopus)

44

Proje

4

Fikri Mülkiyet

1

Tez Danışmanlığı

8

Açık Erişim

19
BM Sürdürülebilir Kalkınma Amaçları